Key Takeaways
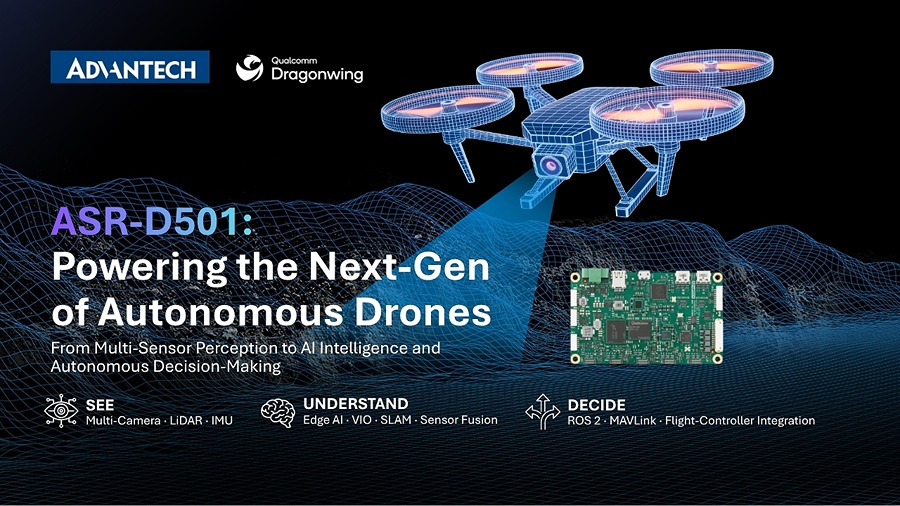
- ASR‑D501 is Advantech’s new AI mission computer built around the Qualcomm QCS6490 SoC, delivering up to 12 TOPS of AI performance while staying under 10 W power draw.
- The board supports five 4‑lane MIPI‑CSI camera links, enabling mixed RGB, mono, stereo, and high‑resolution vision arrays.
- Integrated interfaces cover flight‑controller I/O, sensor buses (I²C, SPI, UART), and optional wireless modules, creating a single‑package solution for autonomous UAVs.
- On‑board inference handles object detection, SLAM, VIO, and GNSS‑denied navigation, reducing dependence on ground‑station or cloud links.
- The Advantech Robotic Suite for Drone provides a ready‑to‑run software stack, cutting development time for vision‑based autonomy.
Advantech’s ASR‑D501: A Compact AI Companion for Autonomous Drones
Overview
Advantech has introduced the ASR‑D501, a purpose‑built mission computer targeting size‑, weight‑, and power‑constrained (SWaP) UAV platforms. The module measures 45 mm × 45 mm × 12 mm and weighs ≈30 g, making it suitable for fixed‑wing, rotary, and hybrid drones that require on‑board intelligence without sacrificing payload capacity.
Power‑Efficient AI Engine
Qualcomm QCS6490 at the Core
- CPU: 8‑core Kryo 680 (2.2 GHz)
- GPU: Adreno 730, 1 TFLOP FP32
- NPU: Hexagon 780, 12 TOPS (int8)
All three compute blocks share a unified memory architecture (LPDDR5, up to 8 GB, 4266 MT/s). The combined design keeps the total board power under 10 W (typical 7.5 W under full AI load), a crucial figure for endurance‑focused drones.
On‑Board Inference Benefits
Processing perception and mission‑level workloads locally eliminates the latency of streaming video to a ground station. The primary flight controller can thus devote its full cycle budget to stabilization, actuator command, and safety monitoring.
Supported AI models include:
- Real‑time object detection (YOLOv5, up to 30 fps @ 720p)
- Semantic segmentation (DeepLabV3+, 15 fps @ 480p)
- Visual‑inertial odometry (VIO) and SLAM (ORB‑SLAM3)
- Anomaly detection for infrastructure inspection
Multi‑Sensor Integration
Vision Front‑End
Five 4‑lane MIPI‑CSI‑2 ports allow flexible camera configurations:
| Camera Type | Typical Resolution | Example Use |
|---|---|---|
| RGB | 4 MP – 12 MP | Object classification |
| Monochrome | 5 MP – 8 MP | Low‑light edge detection |
| Stereo Pair | 2 MP – 6 MP each | Depth estimation for obstacle avoidance |
| High‑Res | 12 MP – 20 MP | Detailed inspection imagery |
The board also includes 2× CAN‑FD, 2× UART, 4× I²C, and 1× SPI ports for lidar, radar, and inertial measurement units (IMUs).
Connectivity & Software Stack
- Wireless Expansion: Optional M.2 slot supports 802.11ax Wi‑Fi, LTE‑Cat 6, or 5G NR modules.
- Advantech Robotic Suite for Drone: Pre‑integrated middleware (ROS 2, OpenCV, TensorRT) with sample pipelines for VIO, SLAM, and GNSS‑denied navigation.
- Secure Boot & TPM 2.0: Guarantees integrity for mission‑critical deployments.
Comparison with Competing UAV Compute Platforms
| Feature | Advantech ASR‑D501 | NVIDIA Jetson Xavier NX | Raspberry Pi Compute Module 4 |
|---|---|---|---|
| AI Throughput | 12 TOPS (int8) | 21 TOPS (FP16) | 0.5 TOPS (CPU only) |
| Power Envelope | ≤ 10 W | 10‑15 W (typ.) | 5‑7 W |
| SWaP (size/weight) | 45 × 45 × 12 mm / 30 g | 70 × 45 × 20 mm / 140 g | 55 × 40 × 4 mm / 15 g |
| Camera Interfaces | 5× 4‑lane MIPI‑CSI | 2× 4‑lane MIPI‑CSI | 1× 2‑lane CSI |
| Flight‑Controller I/O | CAN‑FD, UART, SPI, I²C | CAN, UART, SPI | UART, I²C |
| OS Support | Linux 5.10 (Yocto) | Ubuntu 20.04 LTS | Linux 5.15 (Raspberry Pi OS) |
| Development Kit | Advantech Robotic Suite (ROS 2) | NVIDIA JetPack SDK | Raspberry Pi SDK (Python/C++) |
The ASR‑D501’s niche lies in delivering a balanced AI capability at a lower power budget and with a richer set of vision inputs than most competing modules, while still fitting within ultra‑light UAV frames.
Real‑World Applications
- Infrastructure inspection: On‑board defect detection on power lines or bridges without needing a ground‑station link.
- Search‑and‑rescue: Real‑time victim identification and terrain mapping in GNSS‑denied environments.
- **Agr